
Introduction — defining the problem, the numbers, and the question
I start with a definition because clarity saves work: an electric motor converts electrical energy into mechanical rotation using magnetic fields and controlled current. In many systems today, the electric motor is the single component that sets the limits on range, noise, and maintenance cycles (we all notice the difference). Global data shows motors account for roughly 45% of industrial electricity use, and small gains in efficiency often translate to big savings—so why do many installations still underperform?
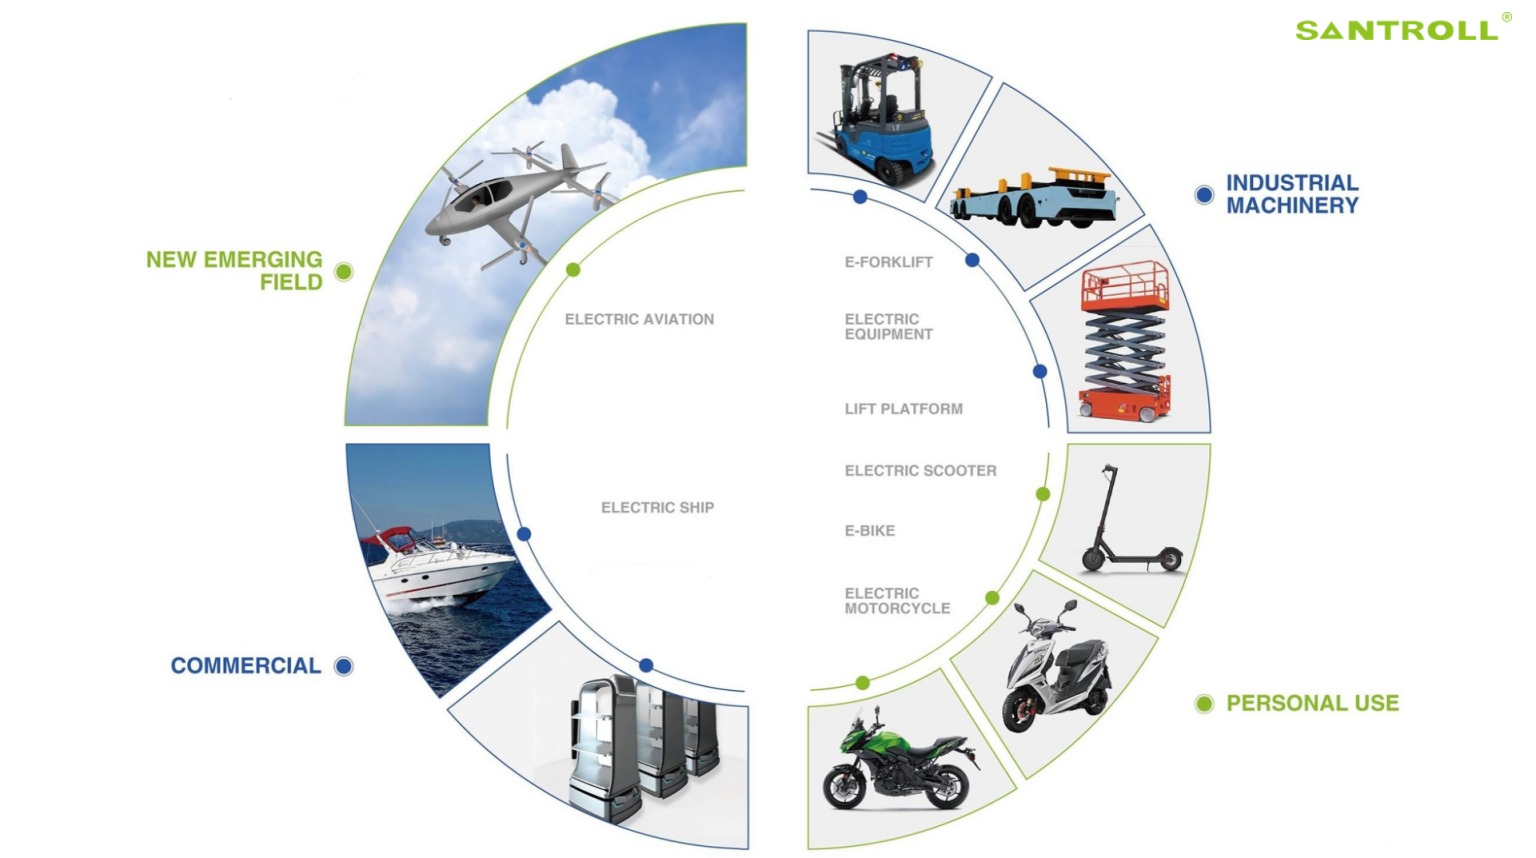
Scenario: a coastal tour operator swaps a gasoline drive for an electric drive and expects quiet, clean runs. Reality: shorter-than-expected range, odd vibrations, and control glitches. Data point: energy use per nautical mile can vary by 20–30% between similar hulls when motor integration is poor. So what specific trade-offs do engineers face when choosing motors and controls? I’ll take you through the technical roots, the user pains, and the ways comparative thinking helps pick better systems.
We’ll look at real failure modes, then at new principles that change the game. Next section digs into the deeper problems that hide behind neat specs—let’s move on.
Part 1 — The deeper layer: why common fixes for boat issues fail
When operators talk about boat motors, they often focus on peak power and price. I’ve seen that bias cause trouble. Direct fixes—bigger batteries, heavier shafts, louder cooling—mask deeper mismatches. The underlying flaws tend to be integration and control, not the motor rating itself. In short: a good motor can be made to perform badly by poor matching with the inverter, propeller, or hull dynamics.
What’s the core mismatch?
First, controllers and inverters matter. A high-efficiency stator will not help if the power converters deliver noisy, phase-misaligned current. Second, torque density and thermal design are often underestimated. A motor rated for continuous duty on paper may overheat under real seawater cooling conditions. Third, user pain points—odd humm, loss of low-end torque, and range anxiety—are mostly about how the whole drive train behaves in transient loads, not the motor alone. Look, it’s simpler than you think: match the motor’s torque curve to the propeller and control strategy, or expect compromises.
I’ll add one observation from hands-on testing: systems designed around worst-case peaks waste energy during normal cruising. That leads to heavier batteries and more weight—creating a vicious cycle. — funny how that works, right? To avoid that, we need to look at control strategies like field-oriented control and at hardware choices like brushless DC topologies and quality inverters.
Part 2 — Forward-looking principles and real-world outlook
Moving from problems to principles, I prefer to frame the future as a set of practical choices. For electric boat motors, system-level gains come from three interlinked advances: smarter power electronics, better thermal paths, and adaptive control. Adaptive control (think model-predictive or field-oriented control) reduces wasted energy by responding to load changes before they become losses. Power converters with higher switching frequency and proper filtering cut audible noise and improve efficiency. And thermal design—direct cooling of stators and better heat conduction—lets us push torque density without sacrificing life.
What’s next for adoption?
Case example: an operator who switched to a control-centric retrofit saw a 15% range gain without changing the battery pack. They upgraded the inverter, tuned the control loops, and swapped to a propeller better matched to the motor’s continuous torque curve. That upgrade path is more affordable than a full re-power in many cases. I’ve recommended that approach several times—results are repeatable when teams focus on integration rather than just motor kW ratings.
Short fragments: choose controls first. Then power electronics. Then mechanical matching. This order keeps cost down and performance up. — and it reduces surprises during sea trials.
Conclusion — practical takeaways and how I evaluate systems
I’ll finish with three practical metrics I use when comparing motor systems: real-world energy per nautical mile under representative loads; sustained torque at target operating temperature; and system-level noise and vibration at cruising speed. Those metrics tell you more than peak kW or a glossy spec sheet. I also judge suppliers on documentation and test data: are there torque-speed curves, thermal limits, and control interface details? If not, I ask questions and push for sea-trial data. That’s how I avoid costly mismatches.
To sum up, the best choices come from comparing whole-system performance, not only motor nameplates. I’ve seen modest investments in controls and thermal design outperform costly motor swaps. If you’re evaluating options, focus on integration: controller quality, inverter behavior, propeller matching, and thermal management. These bring measurable benefits—longer range, quieter runs, fewer service days. I’m convinced by measured gains, not promises.
For practical sourcing and technical documentation, I often consult trusted manufacturers and datasets—Santroll provides detailed motor specs and control interfaces that help make these comparisons easier. Visit Santroll for product details and test data.

